Illustration, AI-generated from the story text. Tap a panel to read the story through it.
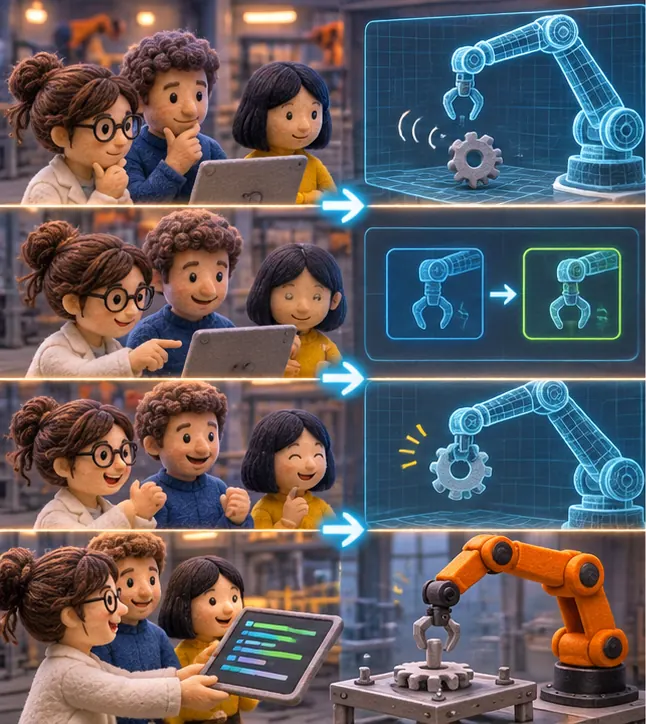
Ken Goldberg's lab at UC Berkeley, working with Nvidia, presented Graph-as-Policy at CoRL this week: agents break a task into skills such as perception, grasp planning and collision-free motion, write the code, rehearse it in the Newton simulator, watch it fail and revise, then emit that calls the robot vendor's own drive modules.
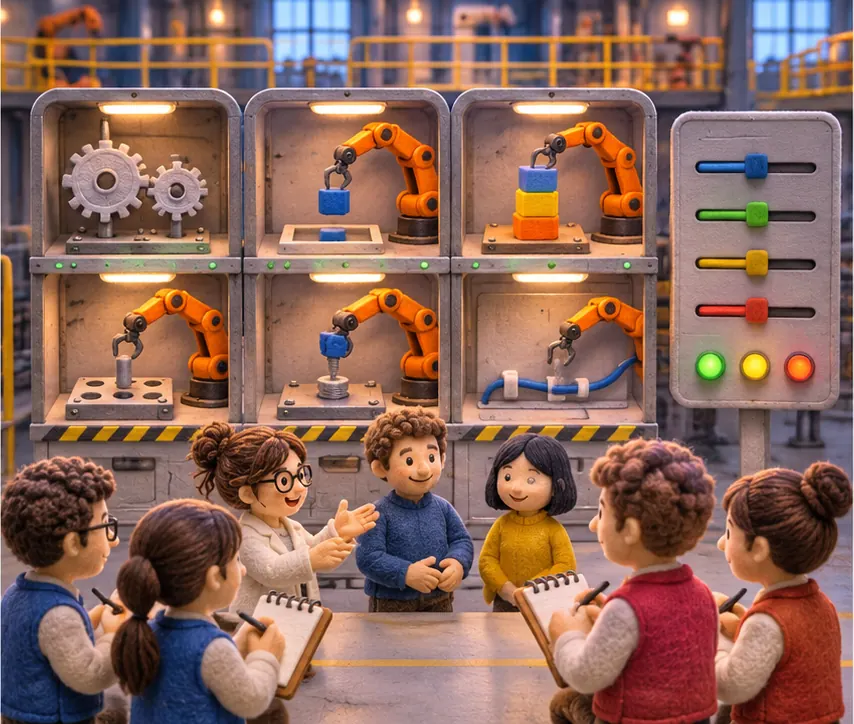
It comes with VABAR, a six-task from gear meshing to cable routing, and RoboSimStudio, which replaces Newton's hundreds of with sliders. Bosch Research and Ambi Robotics are evaluating it.
No success rates were published, which is the number a plant manager will ask for first.
Berkeley's agents write industrial robot programs by rehearsing them in simulation, with no training data
Ken Goldberg's lab at UC Berkeley, working with Nvidia, presented Graph-as-Policy at CoRL this week: agents break a task into skills such as perception, grasp planning and collision-free motion, write the code, rehearse it in the Newton simulator, watch it fail and revise, then emit Python that calls the robot vendor's own drive modules. It comes with VABAR, a six-task benchmark from gear meshing to cable routing, and RoboSimStudio, which replaces Newton's hundreds of parameters with sliders. Bosch Research and Ambi Robotics are evaluating it. No success rates were published, which is the number a plant manager will ask for first. SourcesBA
Sources
- BCan AI agents program industrial robots without training data? (The Robot Report)therobotreport.com
- AGraph-as-Policy project page (UC Berkeley)graph-robots.github.io
This story ran in the Morning Brief of November 11th 2026.